
Development branch
The develop branch contains changes intended for the next GTSAM release and
may include API changes. For production use, choose the latest stable version
from the GTSAM releases. Current
development builds require C++17; Boost support is optional and controlled by
CMake options.
What is GTSAM?
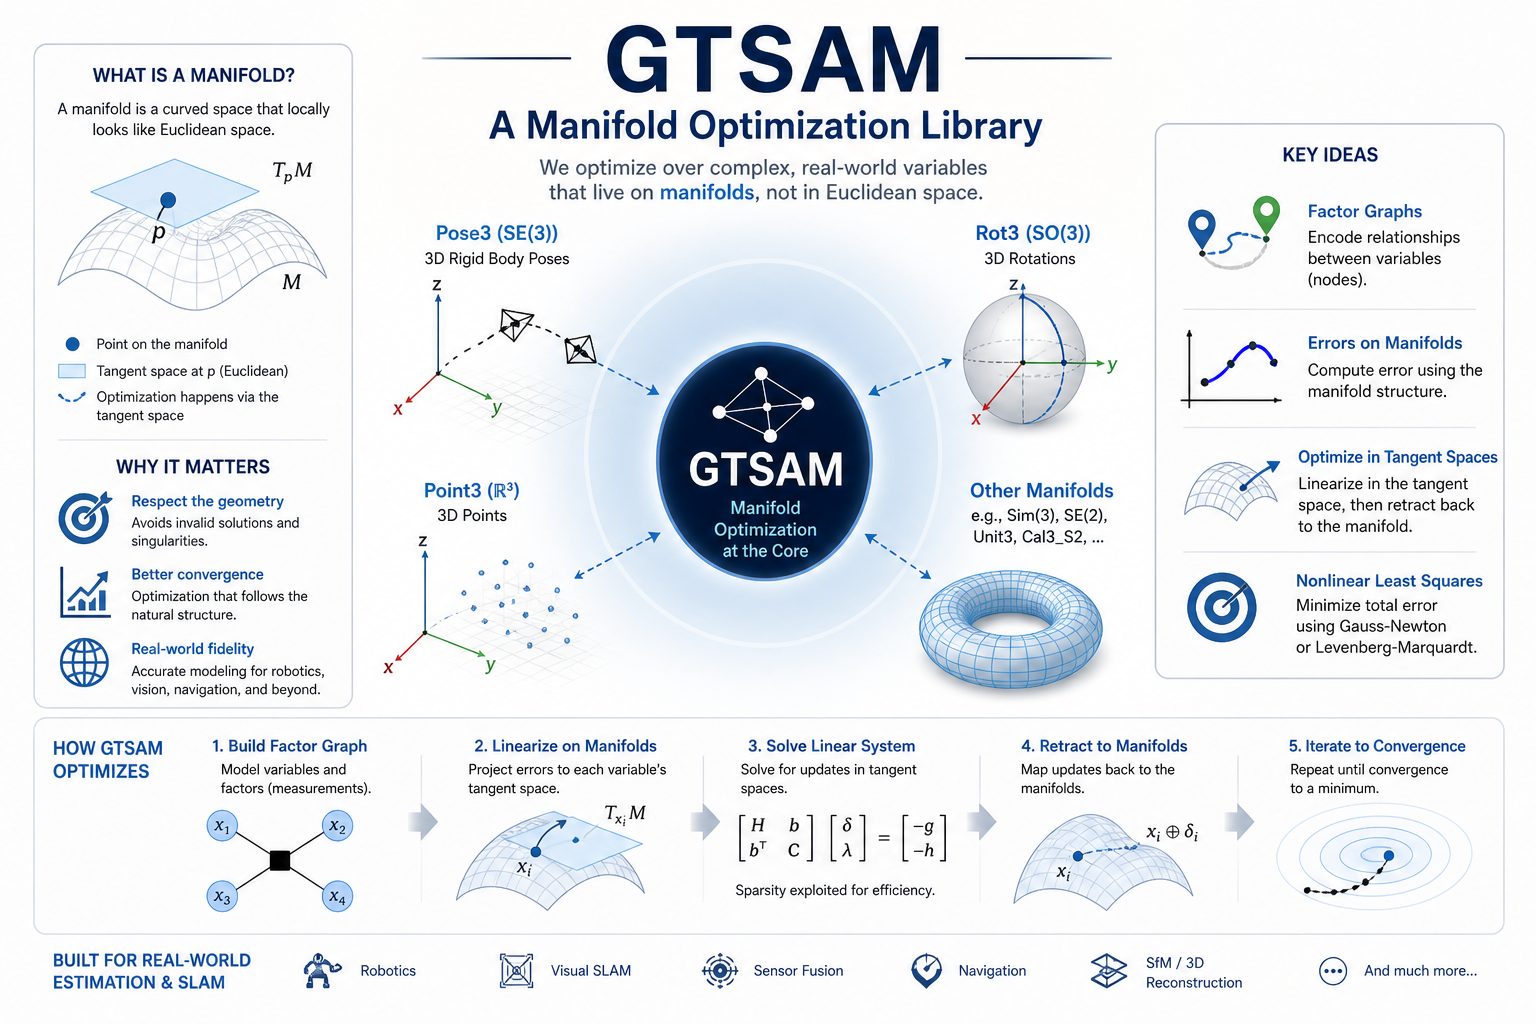
GTSAM is a C++ library that implements smoothing and mapping (SAM) in robotics and vision, using Factor Graphs and Bayes Networks as the underlying computing paradigm rather than sparse matrices.
| CI Status | Platform | Compiler |
|---|---|---|
 | Ubuntu 22.04, macOS 15, Windows 2022 | GCC/Clang/MSVC |
 | Latest Windows/Ubuntu/Mac | - |
 | See pypi files; no Windows | - |
On top of the C++ library, GTSAM includes wrappers for MATLAB & Python.
Documentation
C++ API Docs: https://
gtsam .org /doxygen/ Python API Docs: https://
borglab .github .io /gtsam/ CUDA linear solvers: CUDA
_LINEAR _SOLVERS .md
Quickstart
In the root library folder execute:
cmake -S . -B build
cmake --build build --target check  # optional, runs all unit tests
cmake --build build --target install
Prerequisites:
CMake 3.16 or newer
A compiler with C++17 support. The continuously tested toolchains are:
Linux: GCC 11, 13, 14, or 15 and Clang 11, 14, or 16
macOS: Xcode 16
Windows: MSVC toolset 14.40
Older C++17-capable toolchains may work but are not continuously tested.
Optional Boost prerequisite:
Boost is optional. Two CMake flags govern its use:
GTSAM_USE_BOOST_FEATURES=ON|OFFcontrols the remaining Boost-dependent features.GTSAM_ENABLE_BOOST_SERIALIZATION=ON|OFFcontrols Boost serialization of factor graphs, factors, and related types.
Both options default to ON for ordinary CMake builds and OFF inside ROS 2
builds (colcon, or an install prefix under /opt/ros/). If either option is
ON, install
Boost 1.70 or newer:
macOS:
brew install boostUbuntu:
sudo apt-get install libboost-all-devWindows: use vcpkg, or see HandleBoost.cmake for manual-installation hints.
Optional prerequisites:
oneTBB is searched for when
GTSAM_WITH_TBB=ON, which is the default. On Ubuntu, installlibtbb-dev.Intel oneMKL is used only when
GTSAM_WITH_EIGEN_MKL=ON. See Installation Guide for setup instructions, and benchmark your workload with and without MKL.
GTSAM 4 Compatibility
GTSAM 4 introduced Expressions, a Python toolbox, and traits that allow
optimization with non-GTSAM types. Point2 and Point3 are Eigen vector aliases;
their default constructors do not initialize their coefficients, so initialize
them explicitly before use.
GTSAM_ALLOW_DEPRECATED_SINCE_V43 controls APIs deprecated for the GTSAM 4.3
release and defaults to ON. Disable it while migrating code to identify APIs
scheduled for removal after 4.3.
Wrappers
We provide support for MATLAB and Python wrappers for GTSAM. Please refer to the linked documents for more details.
Citation
If you are using GTSAM for academic work, please use the following citation:
@software{Dellaert26zenodo_GTSAM_4_3,
  author       = {Dellaert, Frank and GTSAM Contributors},
  title        = {GTSAM 4.3.0},
  month        = sep,
  year         = 2026,
  publisher    = {Zenodo},
  version      = {4.3.0},
  doi          = {10.5281/zenodo.22866773},
  url          = {https://doi.org/10.5281/zenodo.22866773},
}
To cite the Factor Graphs for Robot Perception book, please use:
@book{factor_graphs_for_robot_perception,
    author={Frank Dellaert and Michael Kaess},
    year={2017},
    title={Factor Graphs for Robot Perception},
    publisher={Foundations and Trends in Robotics, Vol. 6},
    url={http://www.cs.cmu.edu/~kaess/pub/Dellaert17fnt.pdf}
}
If you are using the IMU preintegration scheme, please cite:
@inproceedings{Forster-RSS-15,
    author    = {Christian Forster and Luca Carlone and Frank Dellaert and Davide Scaramuzza},
    title     = {IMU Preintegration on Manifold for Efficient Visual-Inertial Maximum-a-Posteriori Estimation},
    booktitle = {Proceedings of Robotics: Science and Systems},
    year      = {2015},
    address   = {Rome, Italy},
    month     = {July},
    doi       = {10.15607/RSS.2015.XI.006}
}
The Preintegrated IMU Factor
GTSAM includes a state of the art IMU handling scheme based on
Todd Lupton and Salah Sukkarieh, “Visual-Inertial-Aided Navigation for High-Dynamic Motion in Built Environments Without Initial Conditions”, TRO, 28(1):61-76, 2012. [link]
Our implementation improves on this using integration on the manifold, as detailed in
Christian Forster, Luca Carlone, Frank Dellaert, and Davide Scaramuzza, “IMU Preintegration on Manifold for Efficient Visual-Inertial Maximum-a-Posteriori Estimation”, Robotics: Science and Systems (RSS), 2015. [link]
If you are using the factor in academic work, please cite the publications above.
In GTSAM 4 a new and more efficient implementation, based on integrating on the NavState tangent space and detailed in this document, is enabled by default. To switch to the RSS 2015 version, set the flag GTSAM_TANGENT_PREINTEGRATION to OFF.
Additional Information
There is a GTSAM users Google group for general discussion.
Read about important GTSAM concepts. A primer on GTSAM Expressions, which support efficient automatic differentiation, is available in Expressions.
See the INSTALL file for more detailed installation instructions. Our CI/CD process is detailed in workflows.md.
GTSAM is open source under the BSD license, see the LICENSE and LICENSE.BSD files.
Please see the examples/ directory and the USAGE file for examples on how to use GTSAM.
GTSAM was developed in the lab of Frank Dellaert at the Georgia Institute of Technology, with the help of many contributors over the years, see THANKS.